
Radar sensors detect objects by transmitting radio-frequency signals and analysing the energy reflected from vehicles, people or other surfaces.
Depending on the radar architecture, the sensor can measure distance, radial speed, direction and sometimes elevation. Tracking software can then connect measurements over time to create stable object trajectories.
These capabilities make radar useful in traffic monitoring, speed measurement, perimeter security, industrial automation and sensor-fusion systems. However, not every radar provides the same measurements, output format or detection performance.
Selecting a radar sensor therefore requires more than comparing frequency or maximum range. The application must define which objects need to be detected, what data the system requires and how the sensor will be installed and integrated.
What Is a Radar Sensor?
A radar sensor contains several functional sections:
- Radio-frequency transmitter
- Transmitting and receiving antennas
- Receiver and signal-processing electronics
- Detection and tracking algorithms
- Communication interface
- Power and environmental protection
The transmitter generates a radio signal that travels through the surrounding environment. When the signal reaches an object, part of its energy is reflected toward the radar.
The receiver measures the returned signal. Differences between transmitted and received signals can be used to estimate target properties.
A radar may output raw detections, tracked objects, traffic statistics or preconfigured event alarms. The level of processing depends on the product and intended application.
What Radar Sensors Can Measure
Range
Range describes the distance between the radar and a detected target.
Frequency-modulated radar can estimate range by comparing the transmitted waveform with the delayed received signal. The time or frequency difference is related to the distance travelled by the signal.
Range resolution determines whether two objects at similar distances can be separated. It is affected by signal bandwidth and processing design—not simply by whether the radar operates at 24 GHz, 60 GHz or 77 GHz.
Radial Velocity
The Doppler effect changes the frequency of a reflected signal when the target is moving toward or away from the radar.
This allows the sensor to estimate radial velocity: the component of target speed along the radar’s line of sight.
Radial velocity is not always equal to the vehicle’s actual road speed. If the radar observes the vehicle at an angle, the measured Doppler component must be corrected using the installation geometry or target trajectory.
Azimuth Angle
Azimuth is the horizontal direction of a target relative to the radar.
Radar sensors with multiple antenna channels can estimate the phase difference between received signals and use it to determine target angle.
Angular resolution affects whether the radar can separate vehicles travelling side by side. It is influenced by antenna aperture, channel arrangement, waveform design and signal-processing algorithms.
Elevation Angle
Some radar systems also estimate vertical angle or elevation.
Elevation can help distinguish objects at different heights, estimate target position in three dimensions or improve separation around bridges, slopes and complex structures.
Not every roadside radar requires elevation output. For many traffic applications, accurate ground-plane position, speed and lane assignment are more important.
Signal Strength and Confidence
Radar detections may also include signal strength, signal-to-noise ratio or a confidence value.
A stronger reflection does not automatically mean a larger object. Reflectivity depends on material, shape, orientation, distance and the part of the target facing the radar.
Classification should therefore use multiple features rather than signal strength alone.
CW and FMCW Radar
Continuous-Wave Doppler Radar
A basic continuous-wave radar transmits a signal at a stable frequency and measures Doppler shift.
It is well suited to:
- Measuring target speed
- Detecting vehicle passage
- Triggering speed-feedback signs
- Motion detection
A basic Doppler radar does not directly provide target range. It may also have difficulty distinguishing a stationary object from the static background.
Frequency-Modulated Continuous-Wave Radar
FMCW radar changes its transmitted frequency over time. Comparing the transmitted and received signals allows it to estimate range while Doppler processing estimates radial velocity.
FMCW radar can support:
- Range measurement
- Speed measurement
- Multi-object detection
- Stationary-target detection
- Object tracking
- Lane assignment
- Traffic statistics
- Perimeter-zone monitoring
The exact capabilities depend on bandwidth, antenna design, processing resources and tracking software.
FMCW is widely used where both target distance and movement are required.
Pulsed Radar
A pulsed radar transmits short bursts of radio energy and measures the delay before the reflection returns.
Pulsed systems are common in long-range surveillance and specialised sensing applications. Their suitability for a project depends on pulse design, regulatory requirements, target type and required range.
The waveform name alone does not determine overall performance. Antenna design and processing algorithms remain equally important.
Radar Frequency Bands
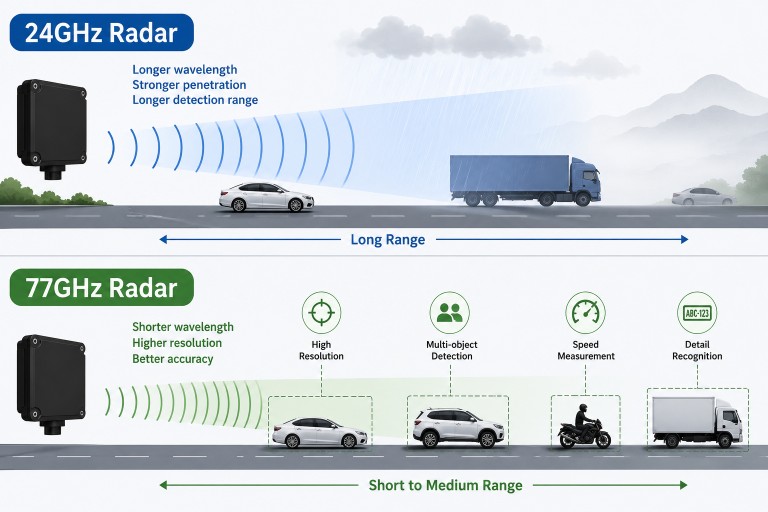
Radar products commonly operate in frequency bands around 24 GHz, 60 GHz and 76–81 GHz, depending on application and regional regulation.
Operating frequency influences antenna size, available bandwidth, packaging and propagation characteristics, but it should not be used as a simple indicator of quality.
For example:
- A higher-frequency radar is not automatically longer range.
- A 24 GHz radar is not automatically less accurate.
- Maximum range depends on transmit power, antenna gain, target reflectivity and processing.
- Range resolution depends strongly on usable signal bandwidth.
- Angular resolution depends heavily on antenna aperture and channel configuration.
The complete sensor architecture must be evaluated.
For a more focused comparison, see 24 GHz vs 77 GHz traffic radar.
From Radar Detections to Object Tracks
A radar detection represents a measurement from one processing cycle. A tracked object combines measurements across multiple cycles.
A typical tracking process contains:
- Detection generation
- Noise and clutter filtering
- Clustering of related points
- Target-state prediction
- Measurement gating
- Data association
- State filtering
- Track confirmation and deletion
Tracking can provide:
- Stable object ID
- X and Y position
- Speed
- Heading
- Acceleration estimate
- Lane assignment
- Trajectory history
- Object dimensions or class
- Track confidence
Tracking quality affects the performance of traffic statistics, camera triggering, wrong-way detection and perimeter alarms.
Read the detailed explanation in Radar Object Tracking: From Raw Detections to Stable Target Tracks.
Radar Output Levels
Two radars with similar detection range may provide very different outputs.
Detection-Level Output
Detection-level data may include individual range, velocity and angle measurements.
It provides flexibility for developers but requires the receiving system to perform clustering, tracking and false-target filtering.
Object-Level Output
Object-level output provides tracked targets with IDs and estimated states.
Typical parameters include:
- Object position
- Speed
- Direction
- Lane
- Target length
- Classification
- Confidence
- Track age
This format is often easier for system integrators because the radar performs much of the tracking internally.
Statistical Output
Traffic radar may convert object data into lane-based statistics such as:
- Vehicle count
- Average speed
- Occupancy
- Headway
- Classification totals
- Queue length
- Traffic flow
Statistical data is useful for traffic management centres, signal control and road-network analysis.
Event Output
Some systems apply additional rules and output events such as:
- Stopped vehicle
- Wrong-way movement
- Intrusion
- Overspeed
- Queue formation
- Target entering a restricted zone
Event output depends on configured rules and should not be assumed from the radar’s detection specification alone.
Radar Sensors for Traffic Monitoring
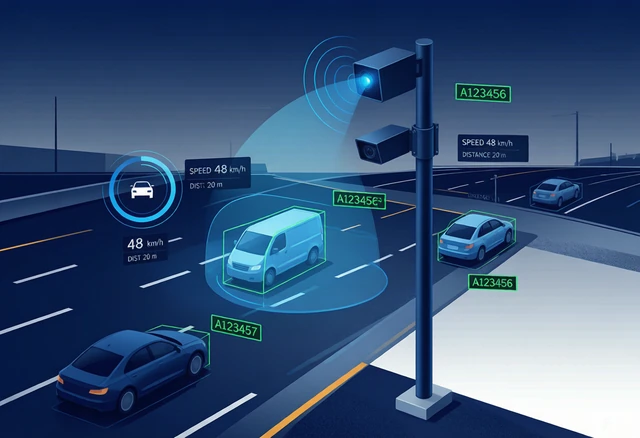
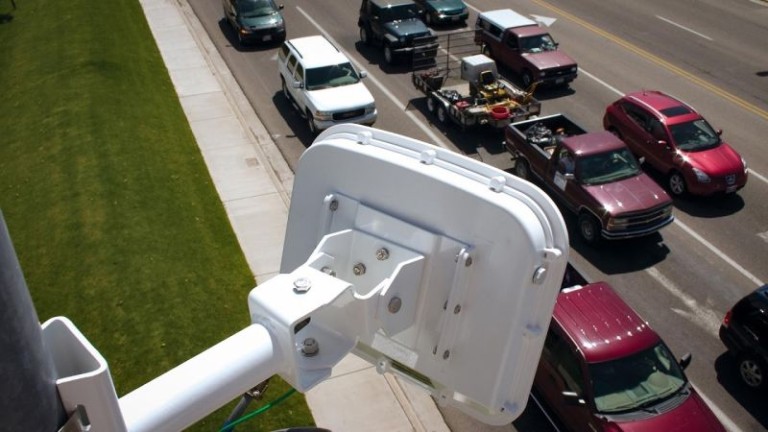
Roadside traffic radar can monitor vehicles without cutting sensors into the road surface.
Depending on the product, it may support:
- Multi-lane vehicle detection
- Traffic volume measurement
- Average and individual speed
- Lane occupancy
- Vehicle headway
- Queue estimation
- Vehicle classification
- Turning-movement statistics
- Wrong-way detection
- Incident-detection input
- Adaptive signal control
- Camera triggering
Radar can be mounted beside the road, above the carriageway or on existing infrastructure. The correct location depends on forward-fire or side-fire geometry, lane count, road curvature and potential occlusion.
For a complete application layout, see the traffic flow monitoring radar solution.
Forward-Fire Traffic Radar
A forward-fire radar observes targets along the direction of travel.
It can provide:
- Long observation distance
- Continuous vehicle trajectories
- Position and speed updates
- Approach monitoring
- Virtual measurement-line events
- Lane-level target information
Large vehicles, curved roads and incorrect mounting angles can still create occlusion or lane-assignment errors.
Side-Fire Traffic Radar
A side-fire radar observes vehicles crossing its field of view from the roadside.
It is commonly used for:
- Multi-lane traffic counts
- Speed statistics
- Vehicle classification
- Occupancy measurement
- Traffic data stations
Whether it supplies continuous target trajectories depends on the specific sensor.
Neither installation geometry is universally superior. It must match the required data.
Radar Sensors for Speed Measurement
Doppler radar can measure vehicle speed directly from frequency shift.
Applications include:
- Speed-feedback signs
- Traffic surveys
- Vehicle-triggered warnings
- Roadside monitoring
- Speed-enforcement system integration
However, measuring speed does not automatically make a sensor a legally approved enforcement instrument.
Enforcement applications may require:
- Certified measurement accuracy
- Controlled installation
- Self-test and diagnostic functions
- Evidence association
- Camera synchronisation
- Secure records
- Jurisdiction-specific type approval
Traffic monitoring and legal enforcement should be treated as different system requirements.
Radar Sensors for Perimeter Security
Security radar monitors people, vehicles or other detectable targets around protected areas.
Applications may include:
- Fence-line monitoring
- Prison perimeters
- Industrial facilities
- Warehouses and logistics areas
- Power and energy sites
- Restricted transport infrastructure
- Open-area intrusion detection
Unlike a simple motion detector, a tracking radar can estimate the target’s position, speed and direction as it moves across a protected area.
The security application can then apply rules based on:
- Target entering a zone
- Direction of movement
- Time inside a restricted area
- Target trajectory
- Speed
- Classification
- Proximity to critical assets
Radar alarms are often combined with cameras. The radar identifies the target position, and the system directs a camera toward the relevant area for visual verification.
See the perimeter security radar solution for a complete integration example.
Radar–Video Fusion
Radar and video provide different types of information.
Radar is strong at:
- Measuring range
- Measuring radial velocity
- Continuous object tracking
- Operation without visible illumination
Video is strong at:
- Visual confirmation
- Appearance-based classification
- Reading visual details
- Providing images to operators
A fusion system may associate radar tracks with image detections to improve event understanding.
Successful fusion requires:
- Time synchronisation
- Coordinate calibration
- Matching fields of view
- Target association
- Consistent object IDs
- Defined behaviour when one sensor loses a target
Using two sensors does not automatically improve the result. Calibration and fusion logic determine whether their information is combined correctly.
Read more about radar–video fusion for roadside monitoring.
Radar Compared With Other Sensors
| Technology | Main strengths | Important limitations |
|---|---|---|
| Radar | Direct range and speed measurement, target tracking, no visible-light requirement | Multipath, occlusion, angular-resolution and configuration limits |
| Camera | Visual detail, classification and operator verification | Lighting, glare, fog, lens contamination and privacy considerations |
| Inductive loop | Reliable detection at a fixed road position | Requires road work and does not provide long continuous trajectories |
| LiDAR | Detailed spatial point clouds and object geometry | Cost, contamination and adverse-weather considerations |
| Passive infrared | Low-power presence or motion sensing | Limited range and sensitivity to environmental temperature conditions |
| Ultrasonic | Simple short-range distance measurement | Limited long-range and multi-target performance |
Sensor selection should be based on the application rather than the assumption that one technology is always superior.
Installation Factors That Affect Performance
Published maximum range is normally measured under defined conditions. Actual performance depends on the site.
Important factors include:
- Mounting height
- Horizontal offset
- Radar yaw and pitch
- Road gradient
- Curvature
- Barriers and metal structures
- Vehicle size
- Target reflectivity
- Large-vehicle occlusion
- Weather exposure
- Vibration
- Nearby radar interference
- Cable and power quality
The site should be assessed before installation, and radar coordinates should be verified against known road positions.
Environmental Performance
Radar does not depend on visible illumination and generally remains useful at night or in reduced visibility.
It should not be described as completely unaffected by the environment.
Possible influences include:
- Severe precipitation
- Water or ice on the radome
- Multipath from wet or metallic surfaces
- Temperature limits
- Wind-induced mounting vibration
- Dirt or physical obstruction
- Electromagnetic interference
- Snow accumulation around the installation
A suitable enclosure, stable mounting and diagnostic monitoring are part of the complete system design.
How to Select a Radar Sensor
Define the Target
Identify what the sensor must detect:
- Passenger cars
- Trucks
- Motorcycles
- Pedestrians
- Cyclists
- Animals
- Drones
- Industrial objects
A vehicle-detection specification should not automatically be applied to pedestrians or small objects.
Define the Detection Area
Document:
- Minimum and maximum distance
- Horizontal field of view
- Required elevation coverage
- Lane or zone geometry
- Mounting position
- Areas that must be excluded
Define the Required Output
Decide whether the integration needs:
- Speed only
- Range and speed
- Target coordinates
- Object tracks
- Lane statistics
- Classification
- Preconfigured alarms
- Raw detection data
Check Update Rate and Latency
Traffic statistics may tolerate longer reporting intervals. Camera triggering, target fusion and active warning systems usually require faster updates and predictable latency.
Update rate should be considered together with measurement stability and communication delay.
Verify Target Capacity
A sensor may work well with one isolated target but become unstable in dense traffic or crowded security scenes.
Confirm:
- Maximum reported targets
- Target-separation performance
- Behaviour during occlusion
- Track recovery
- ID stability
- Output-interface limits
Confirm Communication Compatibility
Ethernet or RS485 specifies the physical communication layer but not the data protocol.
The integrator should also confirm:
- Message structure
- Update format
- Coordinate system
- Time stamps
- Diagnostic information
- Configuration tools
- API or protocol documentation
Conduct a Field Trial
A representative field test should include normal and difficult conditions.
For traffic radar, test:
- Different lanes
- Large and small vehicles
- Dense traffic
- Lane changes
- Stop-and-go traffic
- Maximum required range
For security radar, test:
- Different target routes
- Boundary crossings
- Slow and fast movement
- Temporary occlusion
- Animals or authorised activity
- Camera handoff
WaveLogic Radar Applications
WaveLogic provides radar products for traffic and perimeter-security integration.
The HC-M250 long-range traffic radar supplies target-level vehicle data and lane-based traffic statistics for networked traffic systems. Its current configuration supports monitoring of up to eight lanes, up to 128 targets and a detection distance of up to 300 metres.
The MSR-S200 perimeter security radar is designed to detect and track personnel targets and provide position and trajectory information to an existing security platform.
These products serve different applications. A traffic-monitoring radar should not be selected as a perimeter sensor solely because both products use radar technology.
Common Radar Sensor Misconceptions
Higher frequency always means longer range
Incorrect. Range also depends on transmit power, antenna gain, target reflectivity, receiver sensitivity and processing.
Radar can see through every object
Incorrect. Radar propagation depends on material and frequency. Vehicles, walls and metal structures can block, reflect or distort signals.
Radar is completely unaffected by weather
Incorrect. Radar usually performs more consistently than optical-only systems in darkness and reduced visibility, but environmental and installation conditions can still affect performance.
Every radar can detect stationary objects
Incorrect. Basic Doppler motion sensors may not measure stationary presence. FMCW and other ranging architectures can support stationary-target detection when their processing is designed for it.
Speed measurement means enforcement approval
Incorrect. Legal enforcement normally requires additional measurement, certification and evidence requirements.
Detection means classification
Incorrect. Detecting an object does not automatically identify its class. Classification depends on resolution, target features, algorithms and validation data.
Frequently Asked Questions
What does a radar sensor measure?
Depending on its design, a radar sensor can measure target range, radial speed, azimuth, elevation and reflected-signal strength.
What is the difference between radar detection and tracking?
Detection identifies a measurement during one update. Tracking connects measurements over time to estimate a continuous target state and identity.
Can radar detect stopped vehicles?
A suitable ranging radar with stationary-target processing can detect stopped objects. Basic continuous-wave Doppler sensors generally focus on moving targets.
Can one radar monitor multiple lanes?
Many traffic radar sensors can cover several lanes, but the supported lane count depends on range, field of view, mounting geometry and target separation.
Can radar work without a camera?
Yes. Radar can provide target and traffic data independently. A camera may be added when visual verification or appearance-based classification is required.
Is radar suitable for perimeter security?
Yes, when the radar is designed and configured for personnel or vehicle tracking within security zones. Detection range and classification performance must be validated for the intended targets.
What is the difference between 3D and 4D radar?
Terminology varies. In many current systems, 4D radar refers to measurement of range, radial velocity, azimuth and elevation. The label alone does not define resolution or tracking quality.
Which radar frequency is best?
There is no universal best frequency. Selection depends on permitted regional bands, bandwidth, antenna size, required resolution, range and application.
Conclusion
Radar sensors can provide direct measurements of distance and speed while tracking multiple objects across traffic and security environments.
Their actual value depends on the complete sensing chain: waveform, antenna, detection processing, object tracking, output interface and installation quality.
A good selection process starts with the target, detection area and required output. It then verifies range, resolution, target capacity, latency, communication protocol and environmental suitability through model-level documentation and a representative field test.