An mmWave sensor uses high-frequency radio waves to detect objects and measure information such as range, radial velocity and angle. Unlike a camera, it does not rely on visible illumination. Unlike a basic motion detector, an FMCW mmWave radar can provide distance and, when equipped with suitable antenna channels and processing, target position and multiple-object tracking.
Millimeter-wave radar is used in vehicles, traffic-monitoring systems, security sensors, industrial equipment and building-occupancy applications. However, the term “mmWave sensor” covers products with very different ranges, fields of view, resolutions and output formats.
Choosing the correct sensor therefore requires more than comparing operating frequency or maximum advertised distance.
What Is an mmWave Sensor?
Technically, millimeter waves occupy frequencies from approximately 30 GHz to 300 GHz, corresponding to wavelengths from 10 millimeters down to 1 millimeter.
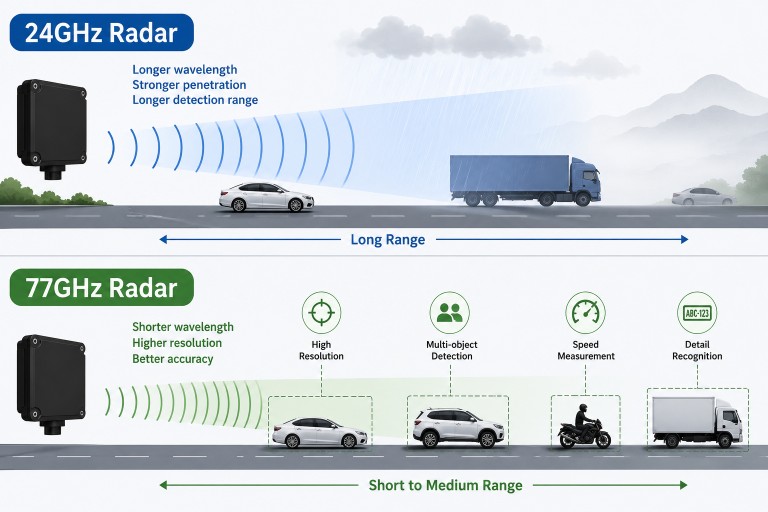
In the commercial radar industry, “mmWave radar” commonly refers to compact high-frequency radar sensors operating in bands such as 60 GHz and 76–81 GHz. Some suppliers also group 24 GHz radar with mmWave products, although 24 GHz falls below the strict millimeter-wave definition.
The operating band does not by itself determine detection range or accuracy. Performance also depends on:
- Transmit power and regulatory limits
- Antenna gain and aperture
- Signal bandwidth
- Waveform and chirp configuration
- Target reflectivity
- Receiver sensitivity
- Signal-processing algorithms
- Mounting geometry and environmental conditions
How Does an mmWave Sensor Work?
Most modern mmWave sensing products use frequency-modulated continuous-wave radar, usually abbreviated as FMCW.
The radar transmits a sequence of signals whose frequency changes over time. These signals are often called chirps. Objects reflect part of the transmitted energy back to the sensor.
The radar compares the transmitted and received signals to derive target information.
Range measurement
The difference between the transmitted chirp and the delayed reflected chirp produces a beat frequency. The processor uses this beat frequency and the chirp slope to estimate target range.
Range resolution describes the ability to separate two targets at similar distances. It is mainly related to swept signal bandwidth, not simply the carrier frequency. A higher carrier frequency does not automatically guarantee finer range resolution.
Velocity measurement
Movement changes the phase of reflected signals across consecutive chirps. Doppler processing uses this change to estimate radial velocity.
Radial velocity is the component of target speed toward or away from the radar. If a vehicle moves at an angle to the radar beam, radial velocity may differ from its actual road speed unless the system accounts for the installation geometry.
Angle measurement
When a radar has multiple receive antennas, a reflected signal reaches each antenna element with a slightly different phase. Direction-of-arrival processing uses these phase differences to estimate target angle.
A horizontal antenna aperture supports azimuth measurement. A suitable vertical aperture is required for elevation measurement. Software alone cannot create true elevation information if the antenna arrangement does not provide the necessary channels.
Detection and tracking
Signal processing identifies peaks or detections in range, velocity and angle. Tracking software then associates detections across successive frames to maintain target IDs and estimate trajectories.
A processed target record may include:
- Target ID
- Range
- Azimuth and, when supported, elevation
- Radial velocity
- Cartesian coordinates
- Direction of travel
- Track age or confidence
- Classification or event information
Not every mmWave sensor provides every field. Some output only motion or presence, while others provide raw detections, point clouds or complete multi-target tracks.
CW Radar vs FMCW mmWave Radar
| Capability | Basic CW Doppler radar | FMCW radar |
|---|---|---|
| Moving-target detection | Yes | Yes |
| Radial velocity | Yes | Yes |
| Target range | Not directly | Yes |
| Stationary-target presence | Normally limited | Possible when supported by processing |
| Detection zones | Usually based on signal level or motion | Can be defined using range and angle |
| Multiple-target tracking | Normally limited | Possible with suitable antenna and processing |
A simple Doppler sensor may be suitable for a speed-feedback sign or motion trigger. Traffic tracking, queue detection and coordinate output normally require range-capable radar and more advanced processing.
What Determines mmWave Radar Range?
There is no universal detection range for an mmWave sensor. Maximum range depends on the complete radar design and the target being detected.
A large vehicle generally produces a stronger reflection than a pedestrian or small object. Detection distance may also change with target orientation, installation angle, rain, radome condition, clutter and the required probability of detection.
When comparing specifications, confirm:
- The type and size of reference target
- Required detection probability
- Allowed false-alarm rate
- Target speed and direction
- Installation height and angle
- Field of view
- Whether the stated value is detection range or reliable tracking range
A target may be detected before it can be positioned, classified or tracked with the accuracy required by the application.
Range, Accuracy and Resolution Are Different
These terms should not be used interchangeably.
- Maximum range is the farthest distance at which a specified target can be detected under defined conditions.
- Range accuracy describes how close a reported distance is to the reference distance.
- Range resolution describes whether two nearby targets can be separated in distance.
- Angular accuracy describes the error in the reported target angle.
- Angular resolution describes whether two targets at similar angles can be distinguished.
A radar may report an accurate angle for one isolated target while still being unable to separate two closely spaced targets. Procurement documents should specify each required performance measure separately.
mmWave Sensor Applications in Traffic Systems
Traffic-flow monitoring
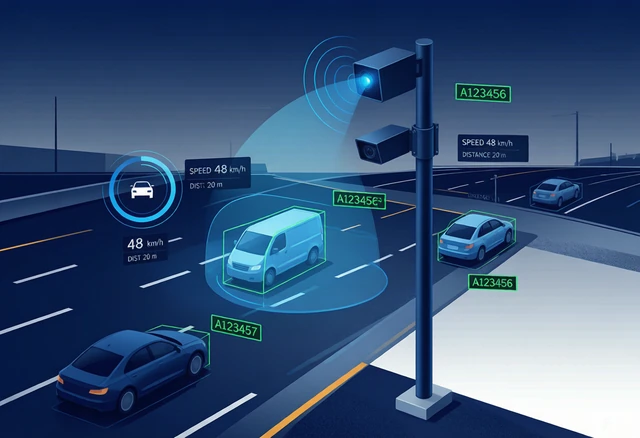
A tracking radar can provide lane-level vehicle count, speed, occupancy, headway and trajectory information. The actual statistics may be calculated inside the sensor or by an external controller using the target list.
For a complete system example, see the traffic flow monitoring solution.
Vehicle speed measurement
Doppler processing measures radial speed directly. Fixed-road installations must account for the angle between the radar beam and the vehicle path.
For camera integration, the system may also require vehicle position, lane assignment, target ID, trigger location and time synchronisation. See the speed enforcement integration solution.
Intersection detection
Range-capable radar can create zones for approaching, waiting and departing vehicles. It may support signal actuation, queue monitoring and approach-speed measurement.
Stationary-vehicle detection must be verified separately. A basic moving-target Doppler sensor should not be assumed to maintain stopped vehicles at a stop line.
Wrong-way and incident detection
Direction and trajectory data can support wrong-way alarms, stopped-vehicle events and abnormal-movement detection. Event reliability depends on zone configuration, tracking continuity and site-specific validation.
mmWave Sensors in Security Systems
Perimeter monitoring
Radar can detect and track people or vehicles across an open area without producing a conventional photographic image. Detection zones and virtual boundaries can generate events for an external security platform.
For a system example, see the perimeter security radar solution.
Radar-camera integration
Radar tracks can direct a camera toward an event or trigger recording. Reliable association requires coordinate calibration, time synchronisation and suitable target-ID logic.
Privacy-sensitive presence sensing
Radar does not capture facial appearance in the way a camera does, but its data may still reveal occupancy, movement or behavioural patterns. Privacy and data-retention requirements should therefore still be considered.
Indoor presence and micro-motion
Short-range mmWave sensors can detect small movements and may support presence, occupancy or activity monitoring. Capability depends on waveform, signal processing, mounting position and the surrounding materials.
mmWave Radar vs Camera, Lidar and Ultrasonic Sensors
| Technology | Strengths | Limitations to consider |
|---|---|---|
| mmWave radar | Direct radial-velocity measurement; operates without visible lighting; range and angle output | Lower appearance detail; multipath, angular resolution and target-association limitations |
| Camera | Rich visual information; colour, markings and detailed classification | Lighting, glare, shadows, fog, contamination and privacy considerations |
| Lidar | Dense spatial measurements and detailed object geometry | Optical-window contamination and reduced performance in some visibility conditions |
| Ultrasonic | Low-cost short-range distance or presence sensing | Limited range, coverage and environmental robustness |
Sensor fusion is useful when one technology cannot provide every required output. Radar may provide speed and trajectory while a camera supplies visual identification. Fusion still requires accurate timing and spatial calibration.
Is mmWave Radar Unaffected by Weather?
No sensor is completely unaffected by its environment.
Radar does not depend on visible illumination and often performs well in darkness, glare and ordinary roadside weather. However, heavy precipitation, water or ice on the radome, environmental clutter and unsuitable installation geometry can affect signal quality.
Claims such as “all-weather” should therefore be supported by defined environmental specifications and field tests rather than treated as absolute guarantees.
Can an mmWave Sensor See Through Walls?
Radio waves can pass through some non-metallic materials, but attenuation depends on material composition, thickness, moisture, frequency and antenna design.
Metal, reinforced structures and many coated materials can block or strongly reflect radar signals. A sensor designed for outdoor traffic detection should not be assumed to provide reliable through-wall sensing.
Any concealed installation must also comply with radio regulations, thermal requirements and the manufacturer’s approved mounting arrangement.
mmWave Sensor Limitations
Occlusion
Large objects can block smaller targets behind them. Higher mounting positions and alternative viewing angles may reduce occlusion but cannot remove it completely.
Multipath reflections
Walls, guardrails, floors and metal structures can create indirect reflection paths. These may generate unstable positions or unwanted detections.
Angular resolution
Closely spaced targets may merge if the effective antenna aperture cannot resolve them. More antenna channels do not automatically guarantee usable resolution unless array design and processing are also suitable.
Stationary-target handling
Some processing chains intentionally suppress stationary reflections to remove clutter. Projects that require queue, stop-line or stationary-person detection must verify how static targets are created, maintained and removed.
Interference
Several radar sensors operating nearby can interfere if their transmissions overlap. The risk depends on waveform timing, frequency use, antenna orientation and interference-mitigation methods.
Regulatory restrictions
Permitted frequency, power, bandwidth and application can vary by country or region. Certification for one market does not automatically authorize use in another.
How to Select an mmWave Sensor
- Define the required output: motion, presence, range, speed, angle, coordinates, tracks, statistics or events.
- Define the targets: vehicles, pedestrians, bicycles, machinery or other objects.
- Specify the scene: number of lanes, target density, road geometry, buildings and reflective structures.
- Check range and field of view: use representative targets and installation conditions.
- Separate accuracy from resolution: define both where necessary.
- Confirm stationary-target behaviour: especially for queue and presence applications.
- Check target capacity: use expected peak traffic or occupancy.
- Review interfaces: confirm protocol, message format, timestamps and status output.
- Confirm regional approval: check frequency and radio certification.
- Define acceptance tests: agree on measurable field criteria before installation.
Integration Questions for System Integrators
Before connecting a radar to another system, confirm:
- Coordinate origin and axis directions
- Distance and speed units
- Lane numbering or zone identifiers
- Target creation and deletion logic
- Timestamp format and clock synchronisation
- Update rate and communication latency
- Network or serial interface
- Fault, status and heartbeat messages
- Configuration backup and recovery
- Firmware and cybersecurity procedures
A radar may measure targets correctly while still producing unusable system results if the controller interprets its coordinates, timestamps or target IDs incorrectly.
How to Validate an mmWave Radar Installation
Commissioning should test the outputs required by the project rather than confirming only that targets appear on a screen.
- Detection by target type and direction
- Range at several known positions
- Speed against a suitable reference
- Lane or zone assignment
- Two-target separation
- Tracking continuity during overtaking
- Stationary-target behaviour
- Dense-scene performance
- Communication interruption and recovery
- Camera or controller association when applicable
Document separate thresholds for detection, position, velocity, classification and tracking. Avoid summarising all performance with one unsupported accuracy percentage.
Frequently Asked Questions
What does an mmWave sensor measure?
Depending on its design, an mmWave sensor can measure range, radial velocity and angle. Tracking software can convert these measurements into coordinates and trajectories.
Is every mmWave sensor an FMCW radar?
No, but FMCW is widely used in compact automotive and industrial mmWave sensors because it supports range and velocity measurement.
Can mmWave radar detect stationary objects?
FMCW radar can measure the range of stationary objects, but the processing chain may suppress static reflections. The required presence behaviour must be confirmed for the specific product.
Does higher frequency always mean longer range?
No. Detection range depends on transmit power, antenna gain, target reflection, receiver design, processing and regulatory limits—not carrier frequency alone.
Is mmWave radar the same as 3D radar?
No. “mmWave” describes a frequency region, while “3D radar” normally describes range, azimuth and elevation measurement. An mmWave sensor may be 1D, 2D or 3D depending on its antenna and processing design. See the 3D radar guide.
Can radar classify vehicles and pedestrians?
Some products provide classification based on track, motion and reflection features. Classification capability and accuracy must be validated separately.
Summary
An mmWave sensor uses high-frequency radar signals to detect objects and measure range, radial velocity and angle. FMCW processing supports distance measurement, while Doppler and antenna-array processing provide velocity and direction information.
Actual performance depends on far more than the operating frequency. Bandwidth, antenna aperture, waveform, tracking software, mounting geometry, target characteristics and regulatory limits all matter.
For a reliable deployment, define the required output first, compare accuracy and resolution separately, confirm integration fields and validate the complete system under representative operating conditions.